|
Yuchen Song (宋雨辰) I'm a 2nd year Ph.D. student at University of California, Irvine, advised by Prof. Unnat Jain. Before that, I obtained my M.S. degree from University of California, San Diego, where I worked with Prof. Xiaolong Wang. My main research interest is intelligent robots (i.e., AI+Robot), which involves a broad collection of topics, e.g., deep learning, reinforcement learning, vision, control, systems design and mechanics, etc. I had the opportunity to intern at Salesforce AI Research in summer 2025, working with Dr. Juan Carlos Niebles and Dr. Michael S. Ryoo. |

|
Research* indicates equal contribution; † indicates equal advising |
|
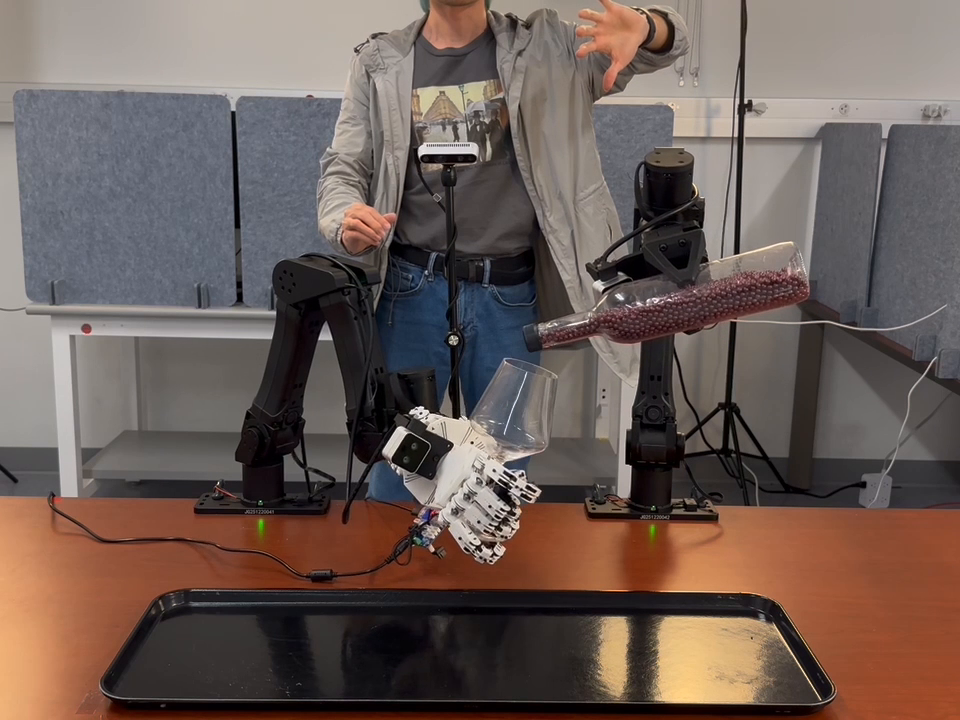
Learning Beyond What Humans Can Demonstrate
Yuchen Song, Aditya Mittal, Unnat Jain CoRL 2026 project page / code / dataset / arXiv Agent generated, iteratively self-refined guardrails helping data collection and policy execution in real time. |
|
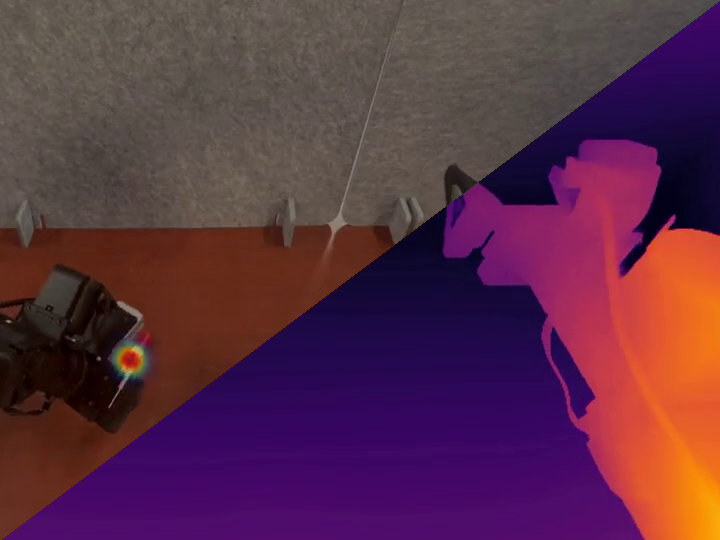
DeVA: Decoupled Video-Action Model with physical guidance for robot policy learning
Mengqi Zhang, Sahil Khose, Simar Kareer, Yuchen Song, Unnat Jain, Judy Hoffman In submission project page / arXiv / code Decoupled video-action model transfers predicted video dynamics into robot actions with affordance and depth supervision. |
|
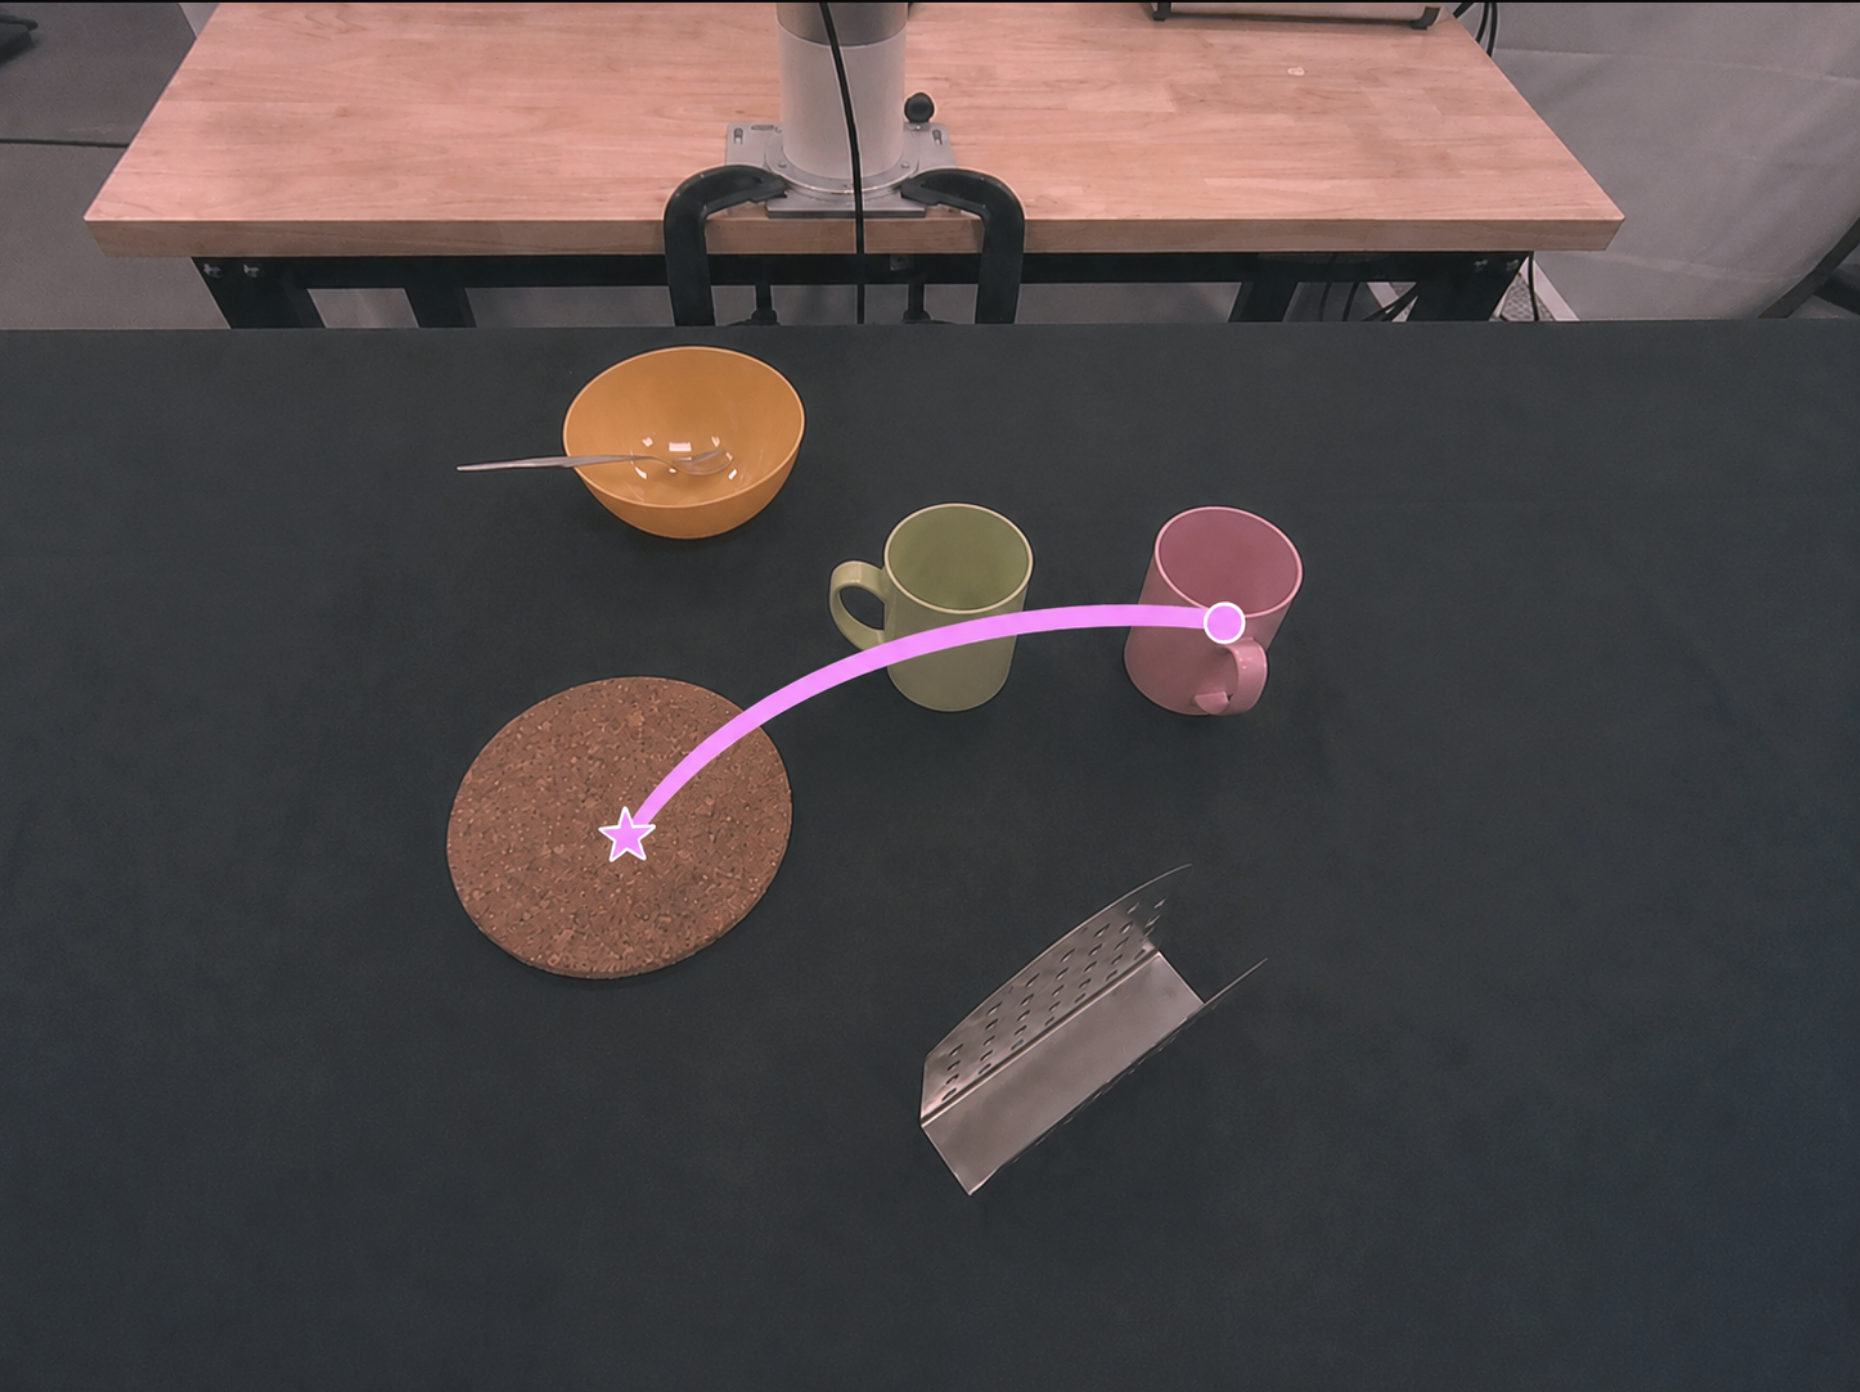
Generalizable VLA Finetuning via Representation Anchoring and Language-Action Alignment
Dwip Dalal, Shivansh Patel, Chahit Jain, Jeonghwan Kim, Utkarsh Mishra, Yuchen Song, Hyeonjeong Ha, Alex Baratian, Heng Ji, Svetlana Lazebnik†, Unnat Jain† In submission project page / arXiv / code Preserving VLM priors and aligning language predictions with action generation during VLA finetuning. |
|
3D-Spatial Multimodal Memory
Xueyan Zou, Yuchen Song, Ri-zhao Qiu, Xuanbin Peng, Jianglong Ye, Sifei Liu, Xiaolong Wang ICLR 2025 project page / arXiv / code Embedding features from foundation models into 3D Gaussian Splatting by omitting redundant information in a memory bank. |
|
|
WildLMa: Long Horizon Loco-Manipulation in the Wild
Ri-zhao Qiu*, Yuchen Song*, Xuanbin Peng*, Sai Aneesh Suryadevara, Ge Yang, Minghuan Liu, Mazeyu Ji, Chengzhe Jia, Ruihan Yang, Xueyan Zou, Xiaolong Wang ICRA 2025 project page / arXiv / video / hardware Long horizon loco-manipulation with LLM planner for wholebody imitation learning skill sets chaining. |
|
|
Learning Generalizable Feature Fields for Mobile Manipulation
Ri-zhao Qiu*, Yafei Hu*, Yuchen Song*, Ge Yang, Yang Fu, Jianglong Ye, Jiteng Mu, Ruihan Yang, Nikolay Atanasov, Sebastian Scherer, Xiaolong Wang IROS 2025 project page / arXiv Real-time generalizable feature fields enabling mobile manipulation with open vocabulary prompts. |


Projects |
|
DS-MVSNeRF
Yuchen Song, Can Chang, Huazhe Xu code Adding depth supervision on Multi-View Stereo Neural Radiance Fields to reduce artificial floaters and achieve better rendering results. |
|
|
Designing & Manufacturing of Robot Cars
Undergrad Course Project index page Designing robot cars with Arduino or STM32 as the main control board to accomplish the assigned tasks, including line tracking, obstacle avoidance, remote controlling, ball shooting, wireless charging, object detection and grasping. |


|
Last update: Nov. 1, 2026. This page was adapted from Jon Barron's website template. |